


Description
The moment you have all been waiting for has finally arrived.
We are happy to announce that the wait for the CAN Commander is finally over
Join the Official Can Commander Discord, run by Matthew, the software guru behind the RL Can Commander: https://discord.gg/djwJ8PF3fc
Looking for a protective yet stylish case for your new can commander, check out our 3D printing partner: Rabbit-Labs Can Commander Case by TRON CASES
We have been working on this board for a little over 2 years now, with the first concept existing a little over 3 years ago. Through hundreds of hours of R&D and thousands of dollars later – we designed the CAN Commander to be a reliable and feature-packed board for harnessing the power of the CAN Protocol.
The premier CAN BUS Flipper board for vehicle repair, hacking, and exploration.
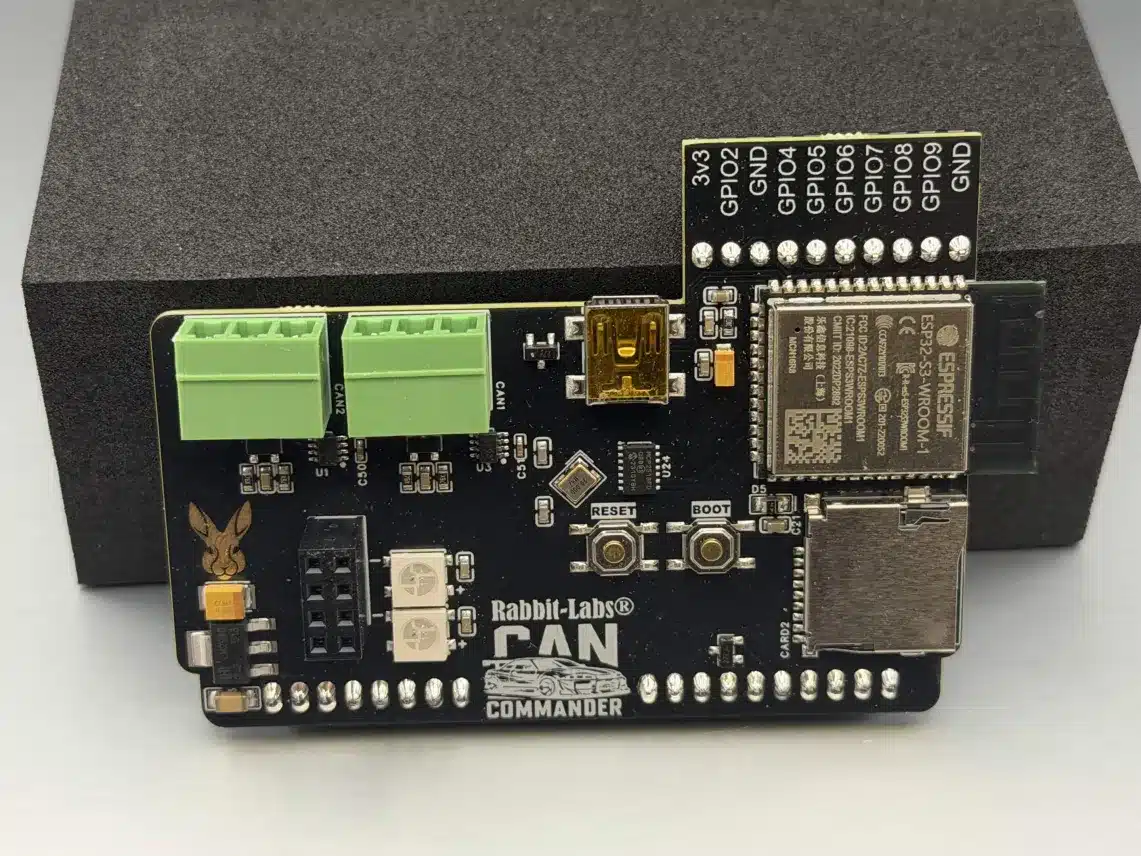
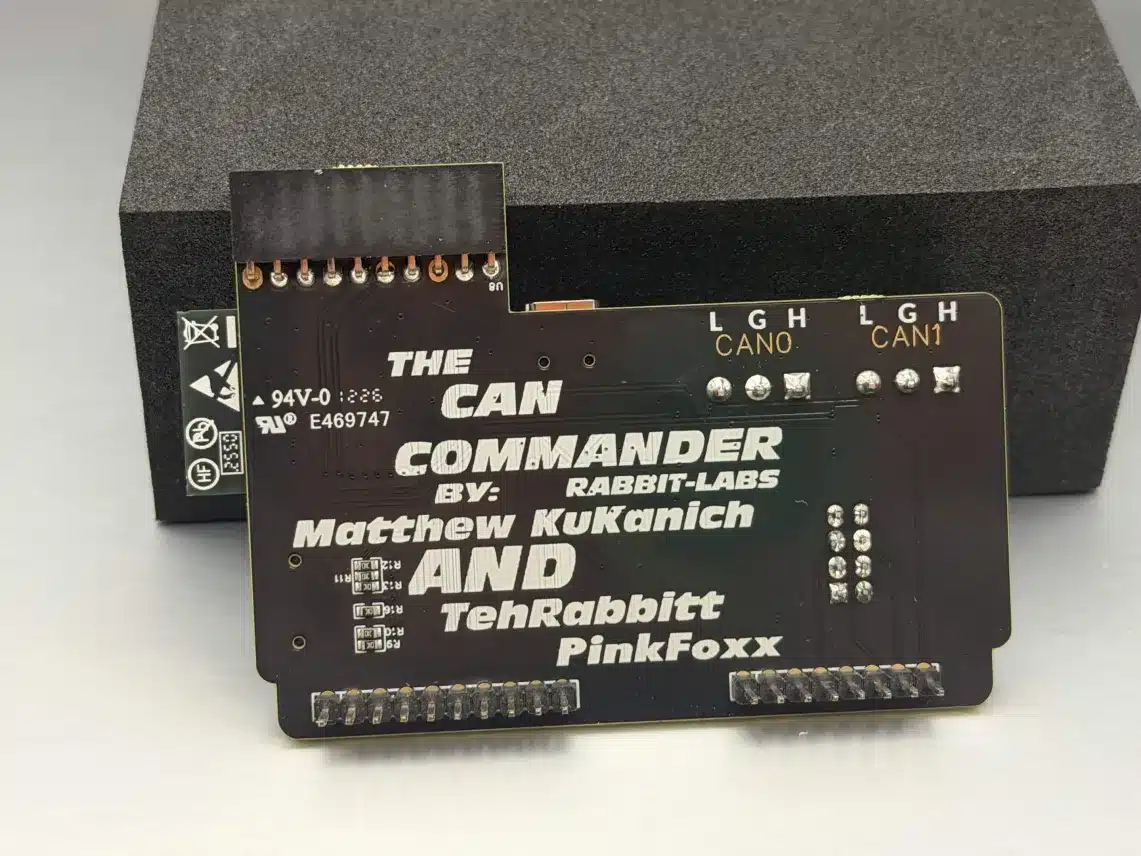
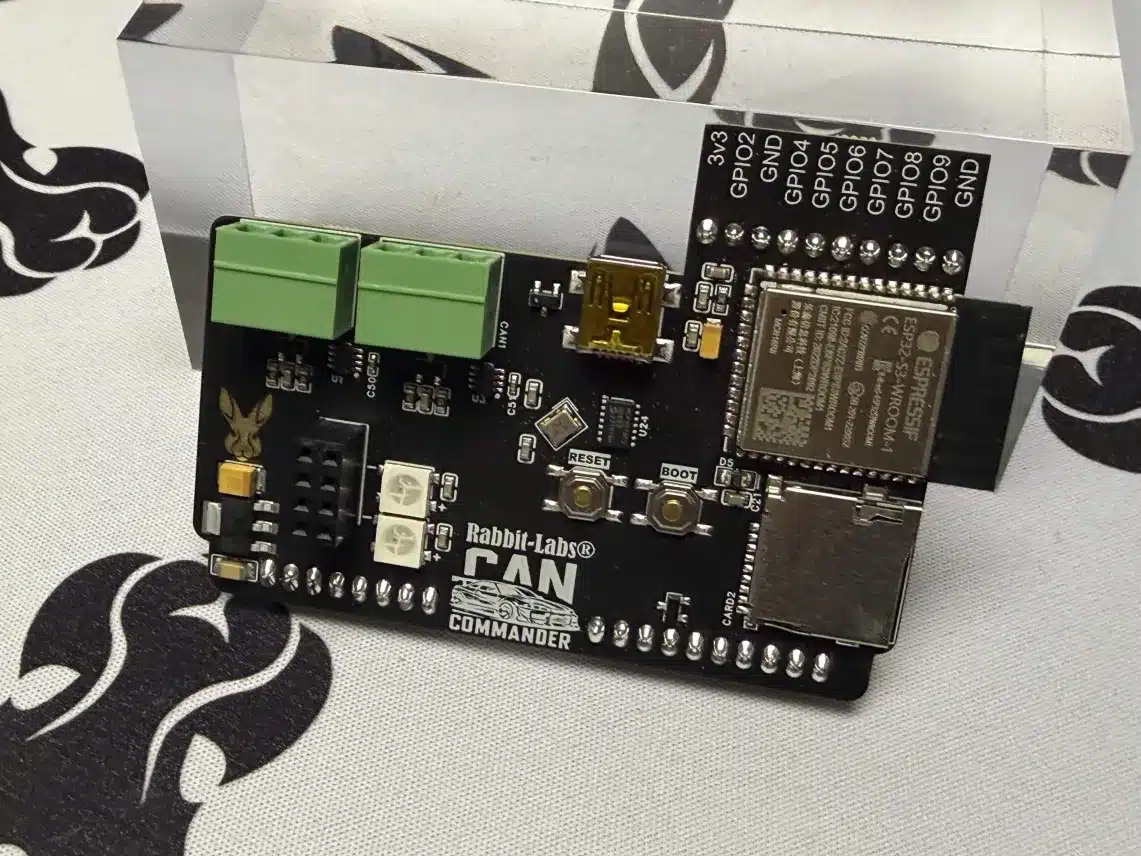
Meet CAN Commander – Rabbit-Labs’ purpose-built CAN platform for Flipper Zero users who want to go deeper than basic sniffing. Whether you’re diagnosing real-world vehicle issues, learning CAN fundamentals, or building advanced tooling for research, CAN Commander is designed to be the board you keep on your bench or in your glovebox!
Okay but who Did we build it for?
- Vehicle diagnostics and repair-minded makers
- Security researchers and CAN enthusiasts
- Flipper Zero users who want a serious CAN platform with room to grow and not just be limited to basic “read-only” functions
Built around the ESP32‑S3 N16R8
At the heart of CAN Commander is the ESP32‑S3 N16R8, a modern, high-performance MCU that’s a perfect fit for CAN work because it delivers without compromise:
- Headroom for real-time CAN workloads: plenty of compute for filtering, decoding, logging, and custom tooling without bogging down when traffic gets busy.
- Flexibility and Future Add-Ons: the ESP32‑S3 ecosystem makes it easy to add new capabilities over time – think smarter analysis and on-device utilities and tools as the CAN Commander software continues to evolve.
- Wireless + connectivity flexibility: ideal for remote monitoring, quick data logging and offload, and building experimental tooling that doesn’t have to stay tethered like other scan tools.
- Memory for serious projects: the N16R8 variant of the ESP32 provides the storage and working memory needed for advanced firmware features, buffers, and real-time CAN injection
High-speed MCP2518FTD controller for clean, reliable bus access
CAN Commander uses the Microchip MCP2518FDT, a modern external CAN controller that works perfectly alongside the ESP32S3
Compared to a lot of common CAN controller modules used in hobby-grade boards, the MCP2518FDT was specially chosen for the CAN Commander because it is a proven solution widely used and well-supported in many vehicle systems “in the real world”, which matters when you’re building a “premier” tool instead of a one-off experiment.
While there are many benefits and reasons we chose this specific controller, the main reasons are that the MCP2518:
- Offloads real CAN timing from the MCU: the MCP2518 handles the CAN protocol engine so the ESP32‑S3 can focus on higher-level work such as decoding, logging, filtering logic, and future features all without getting bogged down by bus traffic.
- Delivers consistent, predictable CAN performance: using a dedicated controller helps keep CAN behavior stable under heavy frames, noisy environments, and “real vehicle” conditions where bit timing and error handling matter.
- Built for high-speed CAN use cases: it’s designed for the kind of traffic you see on REAL automotive networks, not just bench rigs, making it a better foundation than “good enough” controllers you find on amazon and aliexpress that can get flaky when the bus gets busy under real workloads.
But if you’re still not convinced, here’s some of the technical specs of this amazing controller:
- CAN FD + Classical CAN support: supports CAN 2.0B and CAN FD, conforming to ISO 11898-1:2015.
- High-speed operation: arbitration bit rate up to 1 Mbps; data bit rate up to 8 Mbps (CAN FD).
- Fast SPI host interface: SPI clock up to 20 MHz for responsive control/logging
- Deep, flexible message buffering: up to 31 FIFOs that are configurable for transmit or receive preventing dropped frames during bursts of traffic
- Safety/integrity features on the host link: SPI CRC support to detect corruption/noise on the SPI bus
- Built-in diagnostic modes: includes modes like loopback (handy for testing and validation without needing a live vehicle bus).
Dual TI TCAN1044VDDFRQ1 transceivers
Most CAN add-ons stop at a single, basic transceiver. CAN Commander goes further with two Texas Instruments TCAN1044VDDFRQ1 CAN transceivers—chosen for demanding automotive-style environments and real-world work.
What makes the TCAN1044VDDFRQ1 stand out (vs “standard” CAN transceivers):
- Automotive-qualified (AEC‑Q100, Grade 1): built and qualified for harsh vehicle environments; 40°C to 125°C ambient operation.
- Wide junction temp headroom: rated 40°C to 150°C junction, helpful for hot enclosures/under-hood-adjacent installs.
- Standards-compliant physical layer: meets ISO 11898‑2:2016 and ISO 11898‑5:2007 requirements
- Optimized CAN FD performance up to 8 Mbps: supports 2/5/8 Mbps CAN FD with short, symmetrical propagation delays for better timing margin (especially on loaded and noisy buses).
- Serious electrical protection: ±58 V bus fault protection, plus undervoltage protection, TXD dominant timeout (DTO), and thermal shutdown (TSD) all aimed at surviving mistakes and real-world transients.
- Rugged behavior when unpowered: bus and logic pins go high‑impedance (won’t load the bus), and it’s hot‑plug capable with glitch‑free bus/RXD behavior during power up/down.
- Handles real-world ground/common-mode shifts: ±12 V receiver common-mode input voltage, helpful in vehicles where ground offsets can happen.
- High input impedance for big networks: minimum 40 kΩ differential input resistance, supporting heavily populated buses; TI mentions in the datasheet it can theoretically support 100+ nodes on a segment (with proper network design).
Expandability:
1.) 10-pin GPIO header
CAN Commander includes a 10-pin GPIO header to keep the platform expandable – so you’re not buying a dead-end board.
That header is designed to support upcoming Rabbit-Labs add-ons like:
- Dr. Where GPS module (for location-aware logging, GPS Speed calibration, and much more)
- Future Rabbit-Labs modules as the CAN Commander ecosystem grows we will introduce new modules for this header.
2.) 8-pin SPI Pass-Thru header
CAN Commander includes an 8-pin Pass-Thru SPI header allowing the use of your favorite flipper modules such as a CC1101, NRF24, or even a Rabbit-Labs Mini IR Blaster.
Important Legal Information:
The Rabbit-Labs CAN Commander is a professional-grade automotive and research tool. It is not a toy and is not intended for use by minors or untrained individuals. The CAN Commander is intended only for use by qualified mechanics, technicians, engineers, and security researchers who have appropriate training and experience with vehicle electrical systems, in-vehicle networks (including CAN/CAN FD), and the hazards associated with diagnostics, modification, and testing of vehicles and vehicle subsystems.
Vehicle systems can be dangerous. Interacting with, monitoring, injecting, replaying, modifying, or otherwise communicating with vehicle networks and electronic control units (ECUs) may affect vehicle operation, drivability, steering, braking, acceleration, restraint systems, driver assistance features, immobilizers, alarms, emissions controls, charging systems, and other safety-critical or regulated functions. Misuse, misconfiguration, poor workmanship, inadequate testing, or operation in unsafe conditions can result in property damage, loss of vehicle control, serious bodily injury, or death.
By purchasing, possessing, installing, connecting, configuring, powering, or using the CAN Commander (the “Product”), you acknowledge, understand, and agree to all of the following:
1) Professional Use Only; Assumption of Risk
- You represent and warrant that you are competent and legally permitted to use the Product and that you will use it only in a safe manner and only for lawful purposes.
- You are solely responsible for determining whether the Product is appropriate for your intended use and environment, including any use on a vehicle, vehicle subsystem, bench setup, or test network.
- You assume all risks associated with the Product, including risks arising from improper installation, wiring, termination, grounding, power supply selection, firmware/software configuration, data interpretation errors, test methodology, environmental conditions, and third-party components or tools used with the Product.
- Any use of the Product on a vehicle or vehicle subsystem is performed entirely at your own risk.
2) Legal Compliance; No Support for Unlawful Activity
- You are solely responsible for complying with all applicable laws, regulations, rules, and standards (including but not limited to safety, emissions, anti-tampering, cybersecurity, privacy, and consumer protection laws).
- Rabbit-Labs does not condone, authorize, or support unlawful activity. You agree not to use the Product to engage in, facilitate, or attempt any illegal, unauthorized, or improper activity.
3) No Responsibility for Bypassing Interlocks, Safety Systems, Emissions Controls, DRM, or Subscriptions
Without limiting any other provision of this disclaimer, you agree that you will not use the Product to illegally bypass, disable, defeat, circumvent, or tamper with any of the following (whether in whole or in part):
- Dealership or manufacturer interlocks, service locks, or security procedures
- Safety systems or safety-critical features (including but not limited to braking, steering, airbags/SRS, ADAS, immobilizers, alarms, or crash/occupant protection systems)
- Emissions controls, emissions monitoring, or any regulated compliance system
- Digital rights management (DRM), access controls, paywalls, licensing mechanisms, feature-activation controls, or vehicle subscription / feature subscription systems
Rabbit-Labs is not responsible for, and expressly disclaims any liability for, any claims, damages, penalties, fines, losses, or consequences arising from any such use, attempted use, or alleged use.
4) No Liability for Vehicle Damage; No Liability for Injury or Death
To the maximum extent permitted by law:
- Rabbit-Labs is not responsible or liable for any damage to any vehicle, ECU, wiring harness, sensors, actuators, diagnostic ports, tools, equipment, batteries, or other property arising from or related to the purchase, possession, installation, connection, configuration, use, misuse, or inability to use the Product.
- Rabbit-Labs is not responsible or liable for any injury, death, or other loss arising from or related to the purchase, possession, installation, connection, configuration, use, misuse, or inability to use the Product, including but not limited to injuries or death resulting from unsafe testing procedures, operation of a vehicle during testing, or changes to vehicle behavior.
5) “AS IS” / No Warranties
The Product is provided “AS IS” and “WITH ALL FAULTS”. To the maximum extent permitted by law, Rabbit-Labs disclaims all warranties and conditions of any kind, whether express, implied, or statutory, including but not limited to any implied warranties of merchantability, fitness for a particular purpose, title, non-infringement, and any warranties arising from course of dealing or usage of trade.
Rabbit-Labs does not warrant that the Product will be error-free, uninterrupted, secure, compatible with any specific vehicle, ECU, toolchain, firmware, software, or third-party accessory, or that use of the Product will achieve any particular result.
6) Limitation of Liability
To the maximum extent permitted by law, in no event shall Rabbit-Labs be liable for any indirect, incidental, special, consequential, exemplary, or punitive damages, or for any loss of profits, revenue, data, business, goodwill, or vehicle value, arising out of or related to the Product or this disclaimer, even if Rabbit-Labs has been advised of the possibility of such damages.
7) Hold Harmless; Indemnification
To the maximum extent permitted by law, you agree to defend, indemnify, and hold harmless Rabbit-Labs, its owners, employees, contractors, representatives, and affiliates from and against any and all claims, demands, actions, liabilities, damages, losses, judgments, penalties, fines, costs, and expenses (including reasonable attorneys’ fees and costs) arising out of or related to:
- your purchase, possession, installation, connection, configuration, use, misuse, or inability to use the Product;
- any actual or alleged violation of law, regulation, or third-party rights;
- any work performed on any vehicle or vehicle subsystem in connection with the Product;
- any injury, death, or property damage caused by or alleged to be caused by your acts or omissions, or by any third party using the Product under your control.
8) Acceptance; Do Not Use If You Do Not Agree
By using the Product, you acknowledge that you have read, understood, and agree to this disclaimer. If you do not agree, do not use the Product.
Important: Always follow proper automotive safety practices. Do not test on public roads. Use appropriate isolation, protective equipment, and controlled environments.


